Agentic Intelligence Lab

Blog

We periodically release blogs covering topics such as hiring opportunities, introductions to our research results, announcements welcoming new lab members, and yearly summaries of our achievements, and so on.

2026
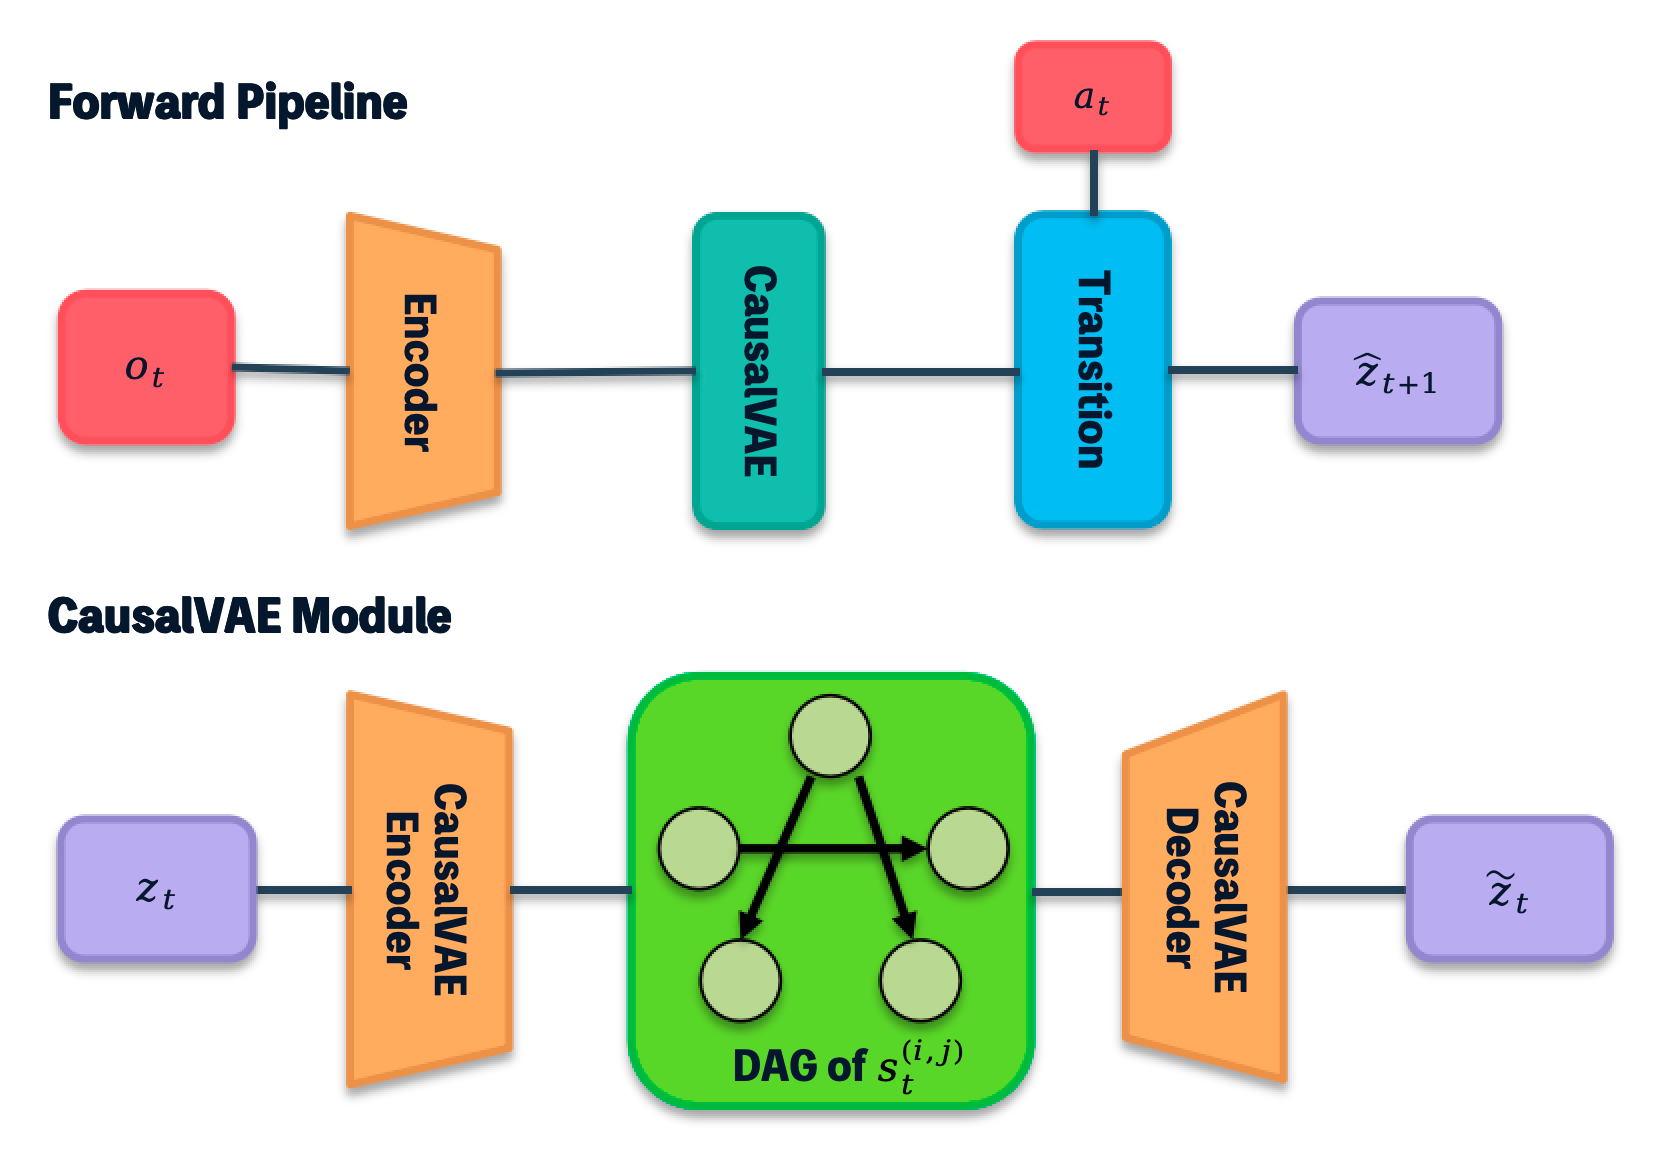
CausalVAE as a Plug-in for World Models: Towards Reliable Counterfactual Dynamics ECCV 2026
CausalVAE as a Plug-in for World Models: Towards Reliable Counterfactual Dynamics (ECCV 2026)

Predicting Is Not Yet Understanding

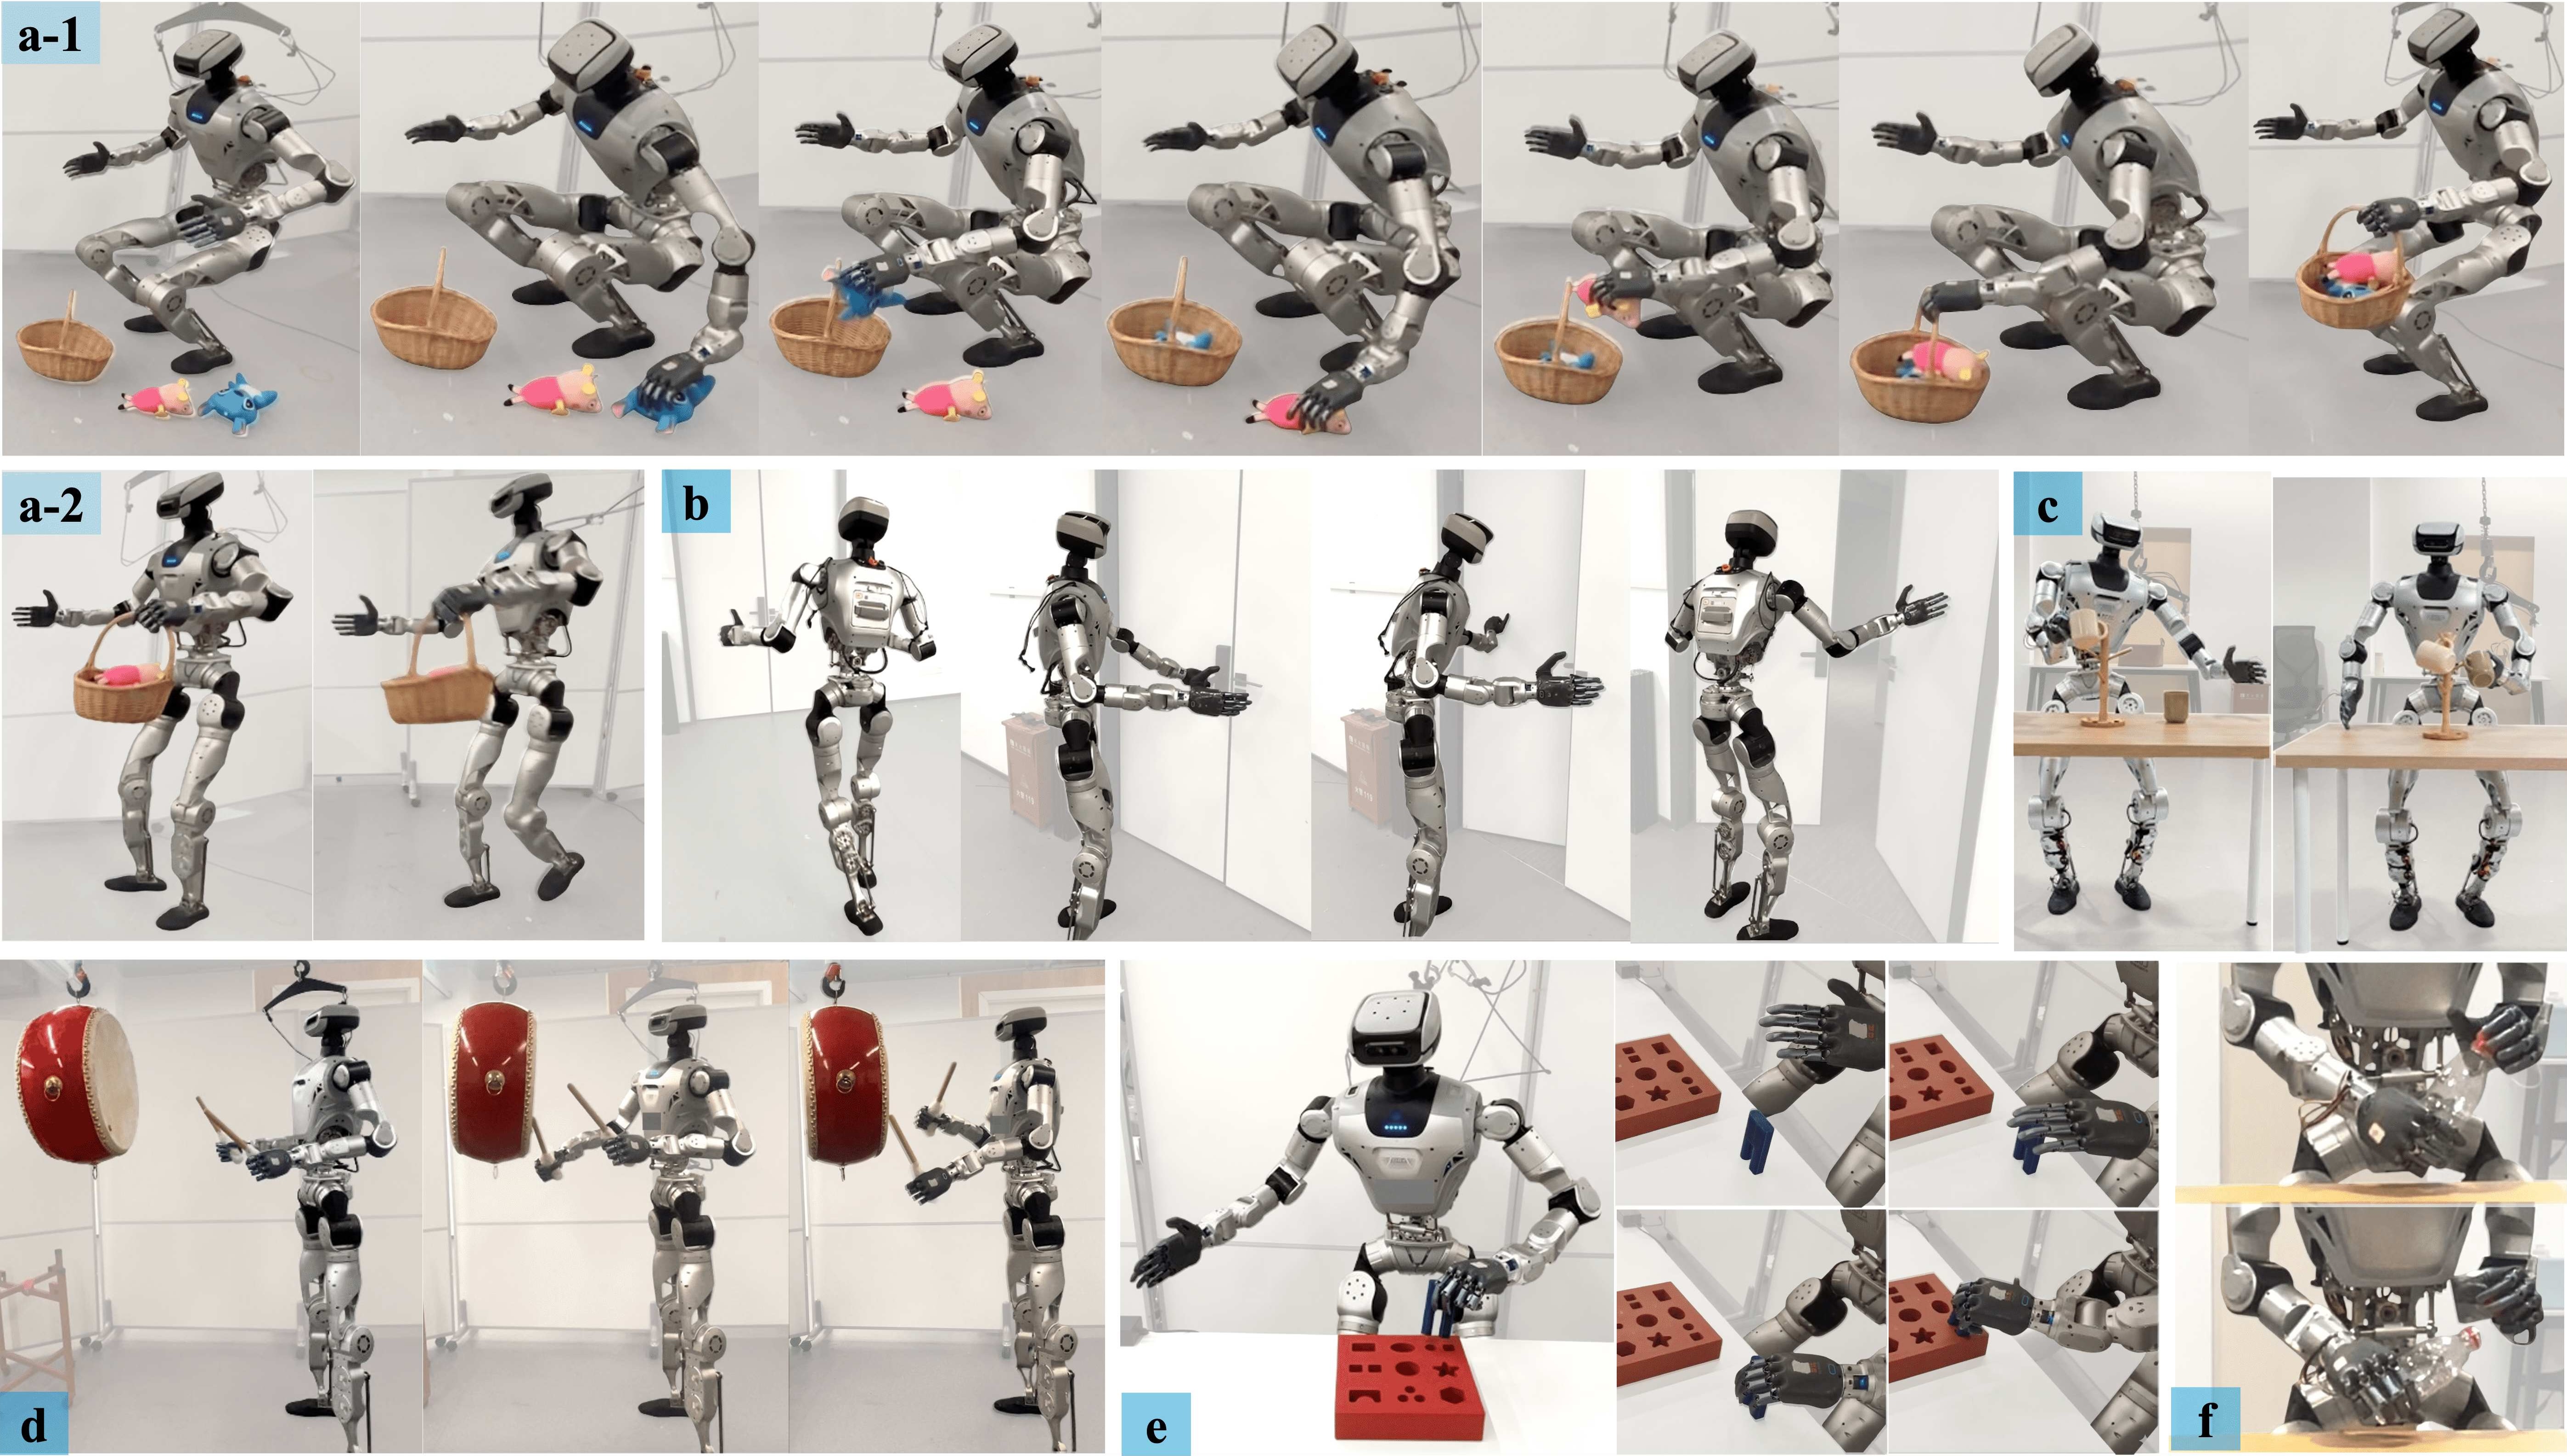
CWI Composite Humanoid Whole-Body Imitation System for Loco-Manipulation RA-L 2026
CWI — Composite Humanoid Whole-Body Imitation System for Loco-Manipulation (RA-L 2026)

One Policy, Two Kinds of Motion Data

ROMBRL Policy-Driven World Model Adaptation for Robust Offline Model-based RL ICML 2026
ROMBRL — Policy-Driven World Model Adaptation for Robust Offline Model-based RL (ICML 2026)

Our paper, “Policy-Driven World Model Adaptation for Robust Offline Model-based Reinforcement Learning”, was presented as a poster at ICML 2026 in Seoul, South Korea. This is joint work between the Agentic Intelligence Lab at the University of Hong Kong, Tsinghua University, and the Robotics Institute at Carnegie Mellon University.

SAIL-RevKL: Stable and Provable Self-Improving Online LLM Alignment UAI 2026
SAIL-RevKL: Stable and Provable Self-Improving Online LLM Alignment (UAI 2026)

Our paper, “On the Convergence of Self-Improving Online LLM Alignment,” appeared at the 42nd Conference on Uncertainty in Artificial Intelligence (UAI 2026). It addresses a basic theoretical gap behind self-improving alignment.

2025

Verlog - A Multi-turn RL framework for LLM agents

Source Code

Available Research Positions at the Agentic Intelligence Lab The University of Hong Kong
Available Research Positions at the Agentic Intelligence Lab @ The University of Hong Kong

About the PI